Richie Ryulie Suganda
Research Assistant · NAIL Lab · University of Houston

NAIL Lab, University of Houston
122 ENGR4 (SAB2)
14000 University Blvd
Sugar Land, TX 77479
Richie R. Suganda is a 3rd year PhD student in Electrical and Computer Engineering at the University of Houston, working in the NAIL Lab (Networked Autonomous & Intelligent Systems Laboratory) under Dr. Bin Hu.
His research focuses on safe and intelligent autonomous systems, with interests spanning multi-robot coordination, control barrier functions, perception-aware planning, and embedded AI. He bridges theory and real-world deployment, developing algorithms for safety-critical robot control, autonomous navigation, and efficient machine learning on resource-constrained platforms.
He is passionate about building systems that are not only intelligent, but also reliable, scalable, and practical for real-world applications.
📍 Cullen College of Engineering · University of Houston
News
2026
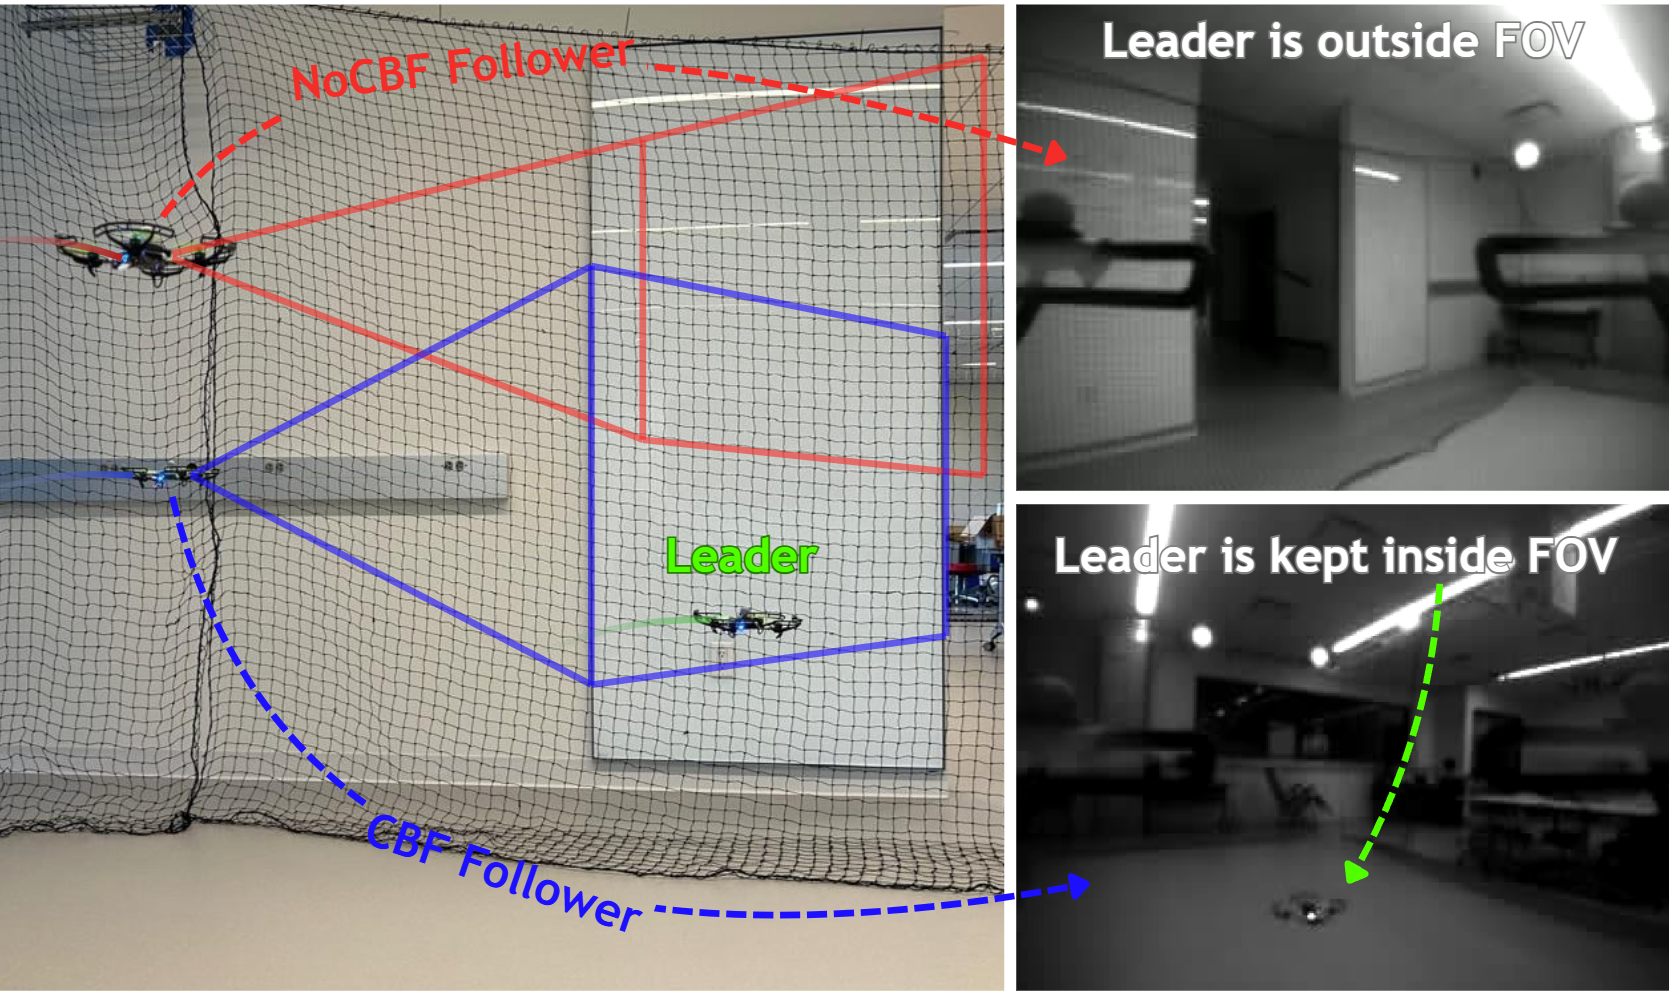
| Sep 07, 2026 | 📄 Distributed 3D Leader-Follower Formation Control with Field-of-View Safety via Control Barrier Functions with Immanuel R. Santjoko, Miao Pan, and Bin Hu accepted as a Late-Breaking Poster at IEEE/RSJ IROS 2026. |
|---|---|
| Sep 07, 2026 | 📄 Adaptive Risk-Certified Event-Triggered Replanning for Dynamic Navigation with Bin Hu accepted at CoRL 2026. |
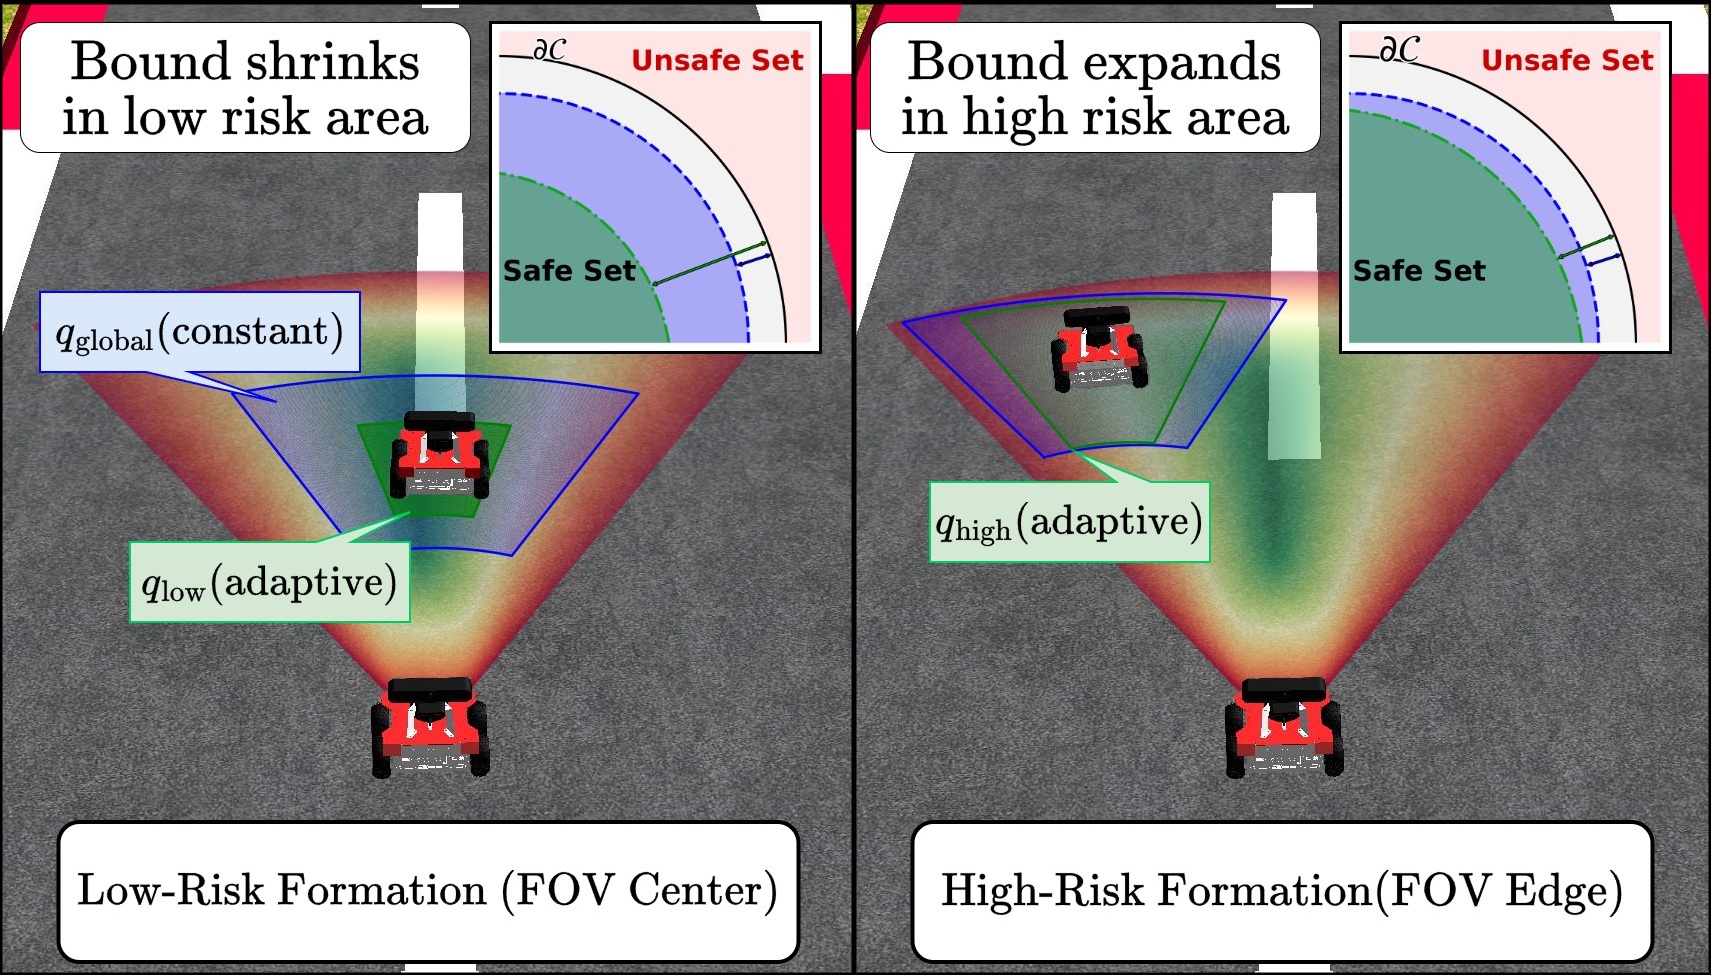
| Aug 07, 2026 | 📄 Formation-Aware Adaptive Conformalized Perception for Safe Leader-Follower Multi-Robot Systems with Bin Hu accepted at IEEE/RSJ IROS 2026. |
| May 20, 2026 | 📄 New preprint: Distributed 3D Leader-Follower Formation Control with Field-of-View Safety via Control Barrier Functions with Immanuel R. Santjoko, Miao Pan, and Bin Hu is now on arXiv. |
| May 20, 2026 | 📄 New preprint: XiYOLO: Energy-Aware Object Detection via Iterative Architecture Search and Scaling with Tony Tran and Bin Hu is now on arXiv. |
| Mar 15, 2026 | 📄 New preprint: Formation-Aware Adaptive Conformalized Perception for Safe Leader-Follower Multi-Robot Systems with Bin Hu is now on arXiv. |
| Jan 15, 2026 | 📄 A High-Fidelity 3D Simulation Environment for Multi-Aircraft Operations with Timothy Bautista, Fengyu Wang, and colleagues accepted at AIAA SCITECH 2026. |
Selected Publications
- CoRLAdaptive Risk-Certified Event-Triggered Replanning for Dynamic NavigationIn 2026 Conference on Robot Learning (CoRL), 2026